Project · Robotics and mechanical design
Two-speed swerve drivetrain
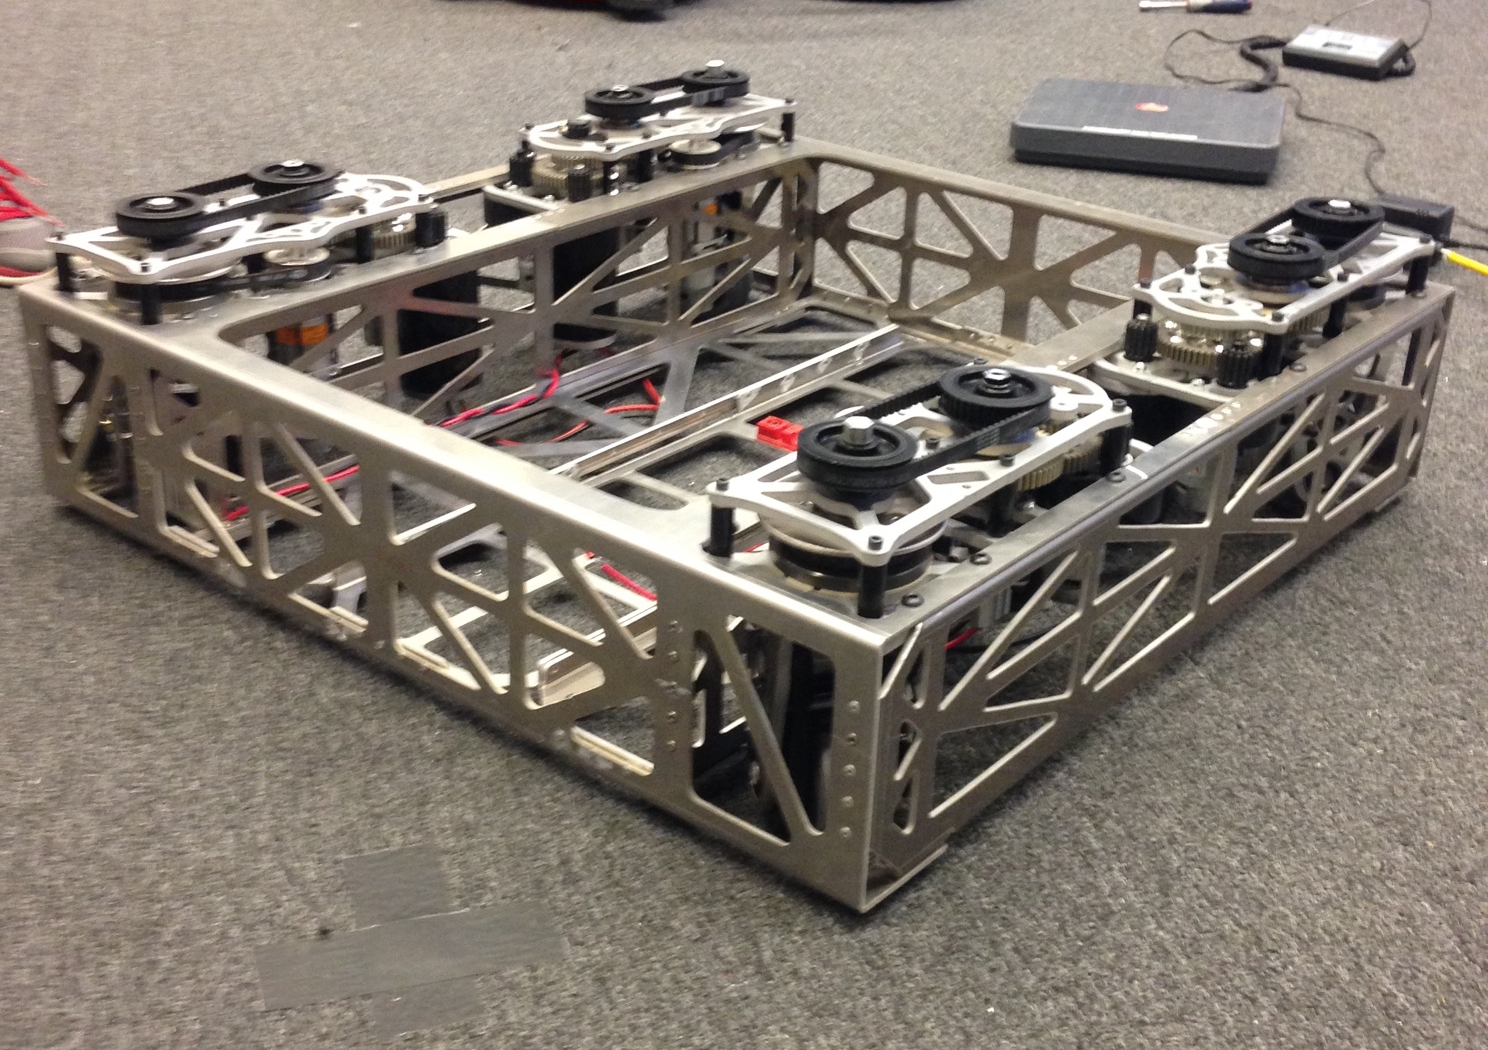
An off-season prototype for FIRST Team 1218, built to explore a compact drivetrain with independently driven and steered wheels.
My role
- Swerve module design
- Gear plates, custom bushings, shafts, and spacers
- Compact geometry designed around the module’s mechanical constraints
- Chassis
- 5052 aluminum cut, bent, and riveted together
- Designed for practical fabrication, assembly, and serviceability
- Manufacturing and assembly — Produced and assembled the mechanical components into a functioning off-season prototype.
- Controls software — Contributed a substantial portion alongside two teammates who also worked on the software.
What it involved
The project connected CAD, machining, assembly, motor control, steering calibration, and testing into one working system. Swerve modules make the boundaries between mechanical alignment and software behavior very visible: small physical inconsistencies become control problems, and software feedback makes the mechanical design useful in practice.